Industrial Robot Preventive Maintenance: A Checklist to Cut Downtime
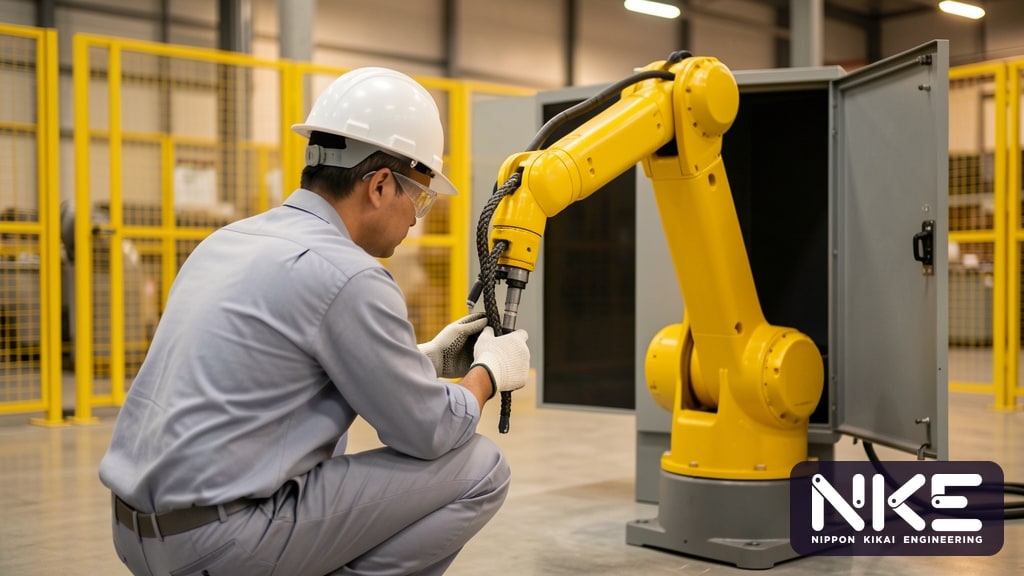
Industrial robots have a reputation for running reliably for years, so many plants install them and then barely touch them, until one stops in the middle of a shift and takes the whole line down with it. A structured industrial robot preventive maintenance (PM) programme is how you catch problems before they turn into unplanned downtime. This article covers the key inspection points, a checklist by interval and the mistakes we see most often, so maintenance teams can put it to work straight away.
Why industrial robot preventive maintenance matters
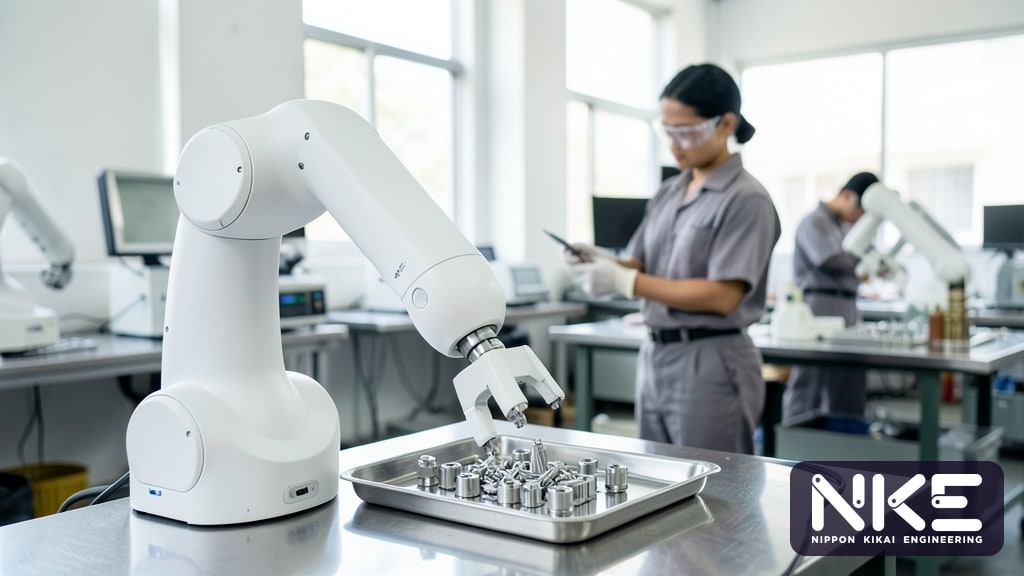
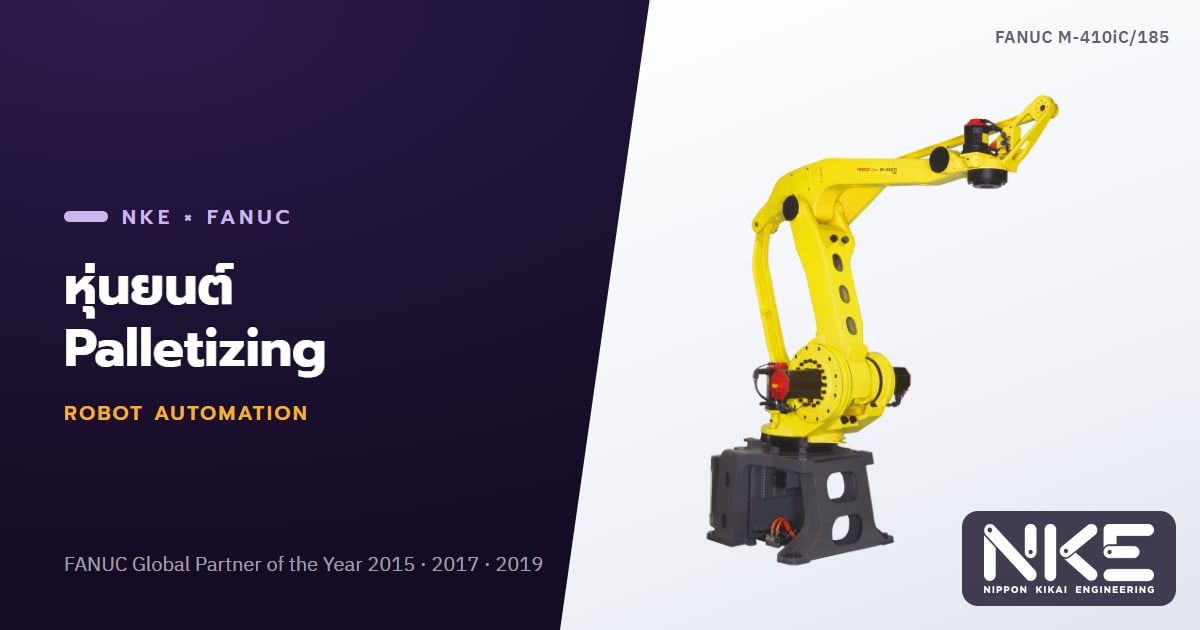
A robot rarely works alone. It loads a CNC machine, stacks cartons on a pallet or feeds the next process. When it stops, everything around it stops too, so the real cost is not just spare parts but lost production hours, rushed deliveries and overtime.
Most robot failures are not sudden. They build up: grease in the reducers degrades, cables at the wrist crack after millions of twists, backup batteries slowly drain. Regular inspection catches these warning signs early, so repairs can be scheduled during planned stops. That ties directly to the Availability factor in OEE.
Key inspection points in a robot cell
1. Mechanical unit, reducers and grease
Each axis has a reducer whose grease must be replaced at the interval the manufacturer specifies, usually defined by both operating hours and calendar time. Use only the grease type listed in the manual, and open the exhaust port as instructed while greasing so internal pressure does not damage the seals. Watch for unusual noise, vibration or grease weeping around the joints.
2. Encoder backup batteries
The pulse coder on each axis motor relies on backup batteries to retain position while the robot is powered off. If they run flat, the robot can lose its position data and need remastering, which takes time and means re-checking every taught point. In general these batteries are replaced with the controller powered on and the emergency stop pressed. Always confirm the procedure in the manual for your model.
3. Cables, air lines and dress pack
Cables running through the wrist and upper arm are bent and twisted every cycle. Look for abrasion, kinks, loose connectors and worn clamps. An intermittent break in a cable typically produces alarms that come and go, which are the hardest faults to trace.
4. Controller cabinet and teach pendant
- Clean or replace air filters and check the cooling fans are running.
- Make sure the cabinet door seals properly and no dust or oil mist is building up inside.
- Inspect the teach pendant cable and its emergency stop button.
- Replace the controller memory backup battery on schedule.
5. End-of-arm tooling and cell equipment
In machine tending cells, the gripper, part-presence sensors, air valves and fixtures often cause more stops than the robot itself. Check air pressure, contact parts such as fingers or suction cups, air leaks, and keep sensors clear of chips and coolant.
6. Safety devices
Test emergency stops, fence door interlocks and light curtains at regular intervals to confirm they still cut power as designed. They do not reduce downtime directly, but they must never be skipped.
PM checklist by interval
The right intervals depend on the robot model, duty cycle and environment. Treat the list below as a starting point and adjust it to the manufacturer's manual.
Daily or start of shift (operators)
- Look and listen for unusual noise or vibration while the robot moves.
- Check for oil or grease leaks around the joints.
- Check air pressure and the condition of the gripper.
- Record any alarms that occurred during the shift.
Monthly or quarterly (maintenance team)
- Inspect cables, air lines and the dress pack in detail.
- Clean filters and check controller fans.
- Test all safety devices.
- Check bolt tightness on the robot base, gripper and fixtures.
- Back up programs and parameters.
By operating hours or annually
- Replace reducer grease as specified in the manual.
- Replace encoder and memory backup batteries.
- Check backlash on each axis and compare reference positions against recorded values.
Common robot maintenance mistakes
- Replacing encoder batteries with the power off, wiping position data and forcing a remaster.
- Greasing without opening the exhaust port, or using the wrong grease, which can damage seals and cause leaks later.
- No program backups, so a memory problem means re-teaching everything.
- Maintaining the robot but ignoring the gripper and cell equipment, which are frequent sources of stops.
- No critical spares on hand, such as batteries, gripper fingers, sensors or air valves, leading to long waits.
- No maintenance history, so recurring alarms go unnoticed.
Using data to plan PM and reduce downtime
Effective PM comes from knowing why machines stop, how often and for how long, not from a checklist alone. Collecting data with a machine monitoring system shows status, stop times and alarm history for both robots and CNC machines in the same cell, so the maintenance team can prioritise based on facts.
Practical steps include:
- Group stop causes, such as robot, gripper, CNC machine or material supply, and tackle the biggest time-loser first.
- Compare cycle time against the standard. A gradual slowdown can point to a mechanical issue or waiting on signals.
- Schedule major PM tasks during planned line shutdowns so production is not affected.
- Train operators to perform daily checks and report anything unusual early.
If you are planning a new cell, design for maintenance access from the start: space to open the controller cabinet, sensible cable routing and quick gripper changes. See more on cell design on our factory automation page.
FAQ
How often should robot grease be replaced?
It depends on the robot model, operating hours and load. The manufacturer sets intervals in the maintenance manual, usually by both hours and calendar time. Robots under heavy duty or in hot environments may need closer attention. Always follow the manual for your specific model.
Can our in-house maintenance team handle robot PM?
With proper training, most daily and monthly checks can be done in-house. Tasks that affect position or the mechanical structure, such as remastering, motor replacement or reducer replacement, are best handled by technicians experienced with that model.
The robot keeps alarming but still runs. What should we do?
Do not just reset and carry on without a record. Note the alarm code, the time and what happened just before. Recurring alarms often point to cables, sensors or the gripper, and a history makes root-cause analysis much faster.
If you want help building a PM plan for your robot and CNC cells, or designing a new cell that is easy to maintain, NKE's engineering team, a FANUC Global Partner, is happy to talk. Call 02-746-7196, add LINE @nke.th or send us a message through our contact form.